I am a senior at Tsinghua University, majoring in Theoretical and Applied Mechanics
with a minor in Mathematics. This fall I am a visiting research assistant at Duke University,
working with Prof. Xiang Cheng. In Spring 2025 I was an exchange student at
Princeton University, where I worked with Prof. Christine Allen-Blanchette.
I have also worked with Prof. Tao Du at Tsinghua IIIS.
I work on theory and methods for flow-based generative models, including guidance,
reward-based fine-tuning, and sampling. I am also interested in stochastic processes on
manifolds and in generative modeling with physical and geometric structure. My projects
so far have studied the consistency between guided sampling and reward fine-tuning of
diffusion models, Hamiltonian latent dynamics for trajectory and video generation, and
generative design for origami.
Jiayin Liu, Zeyu Michael Li, Bingshuo Qian, Xiang Cheng
Under reviewDuke University, with Prof. Xiang Cheng · Jul 2026 – Oct 2026
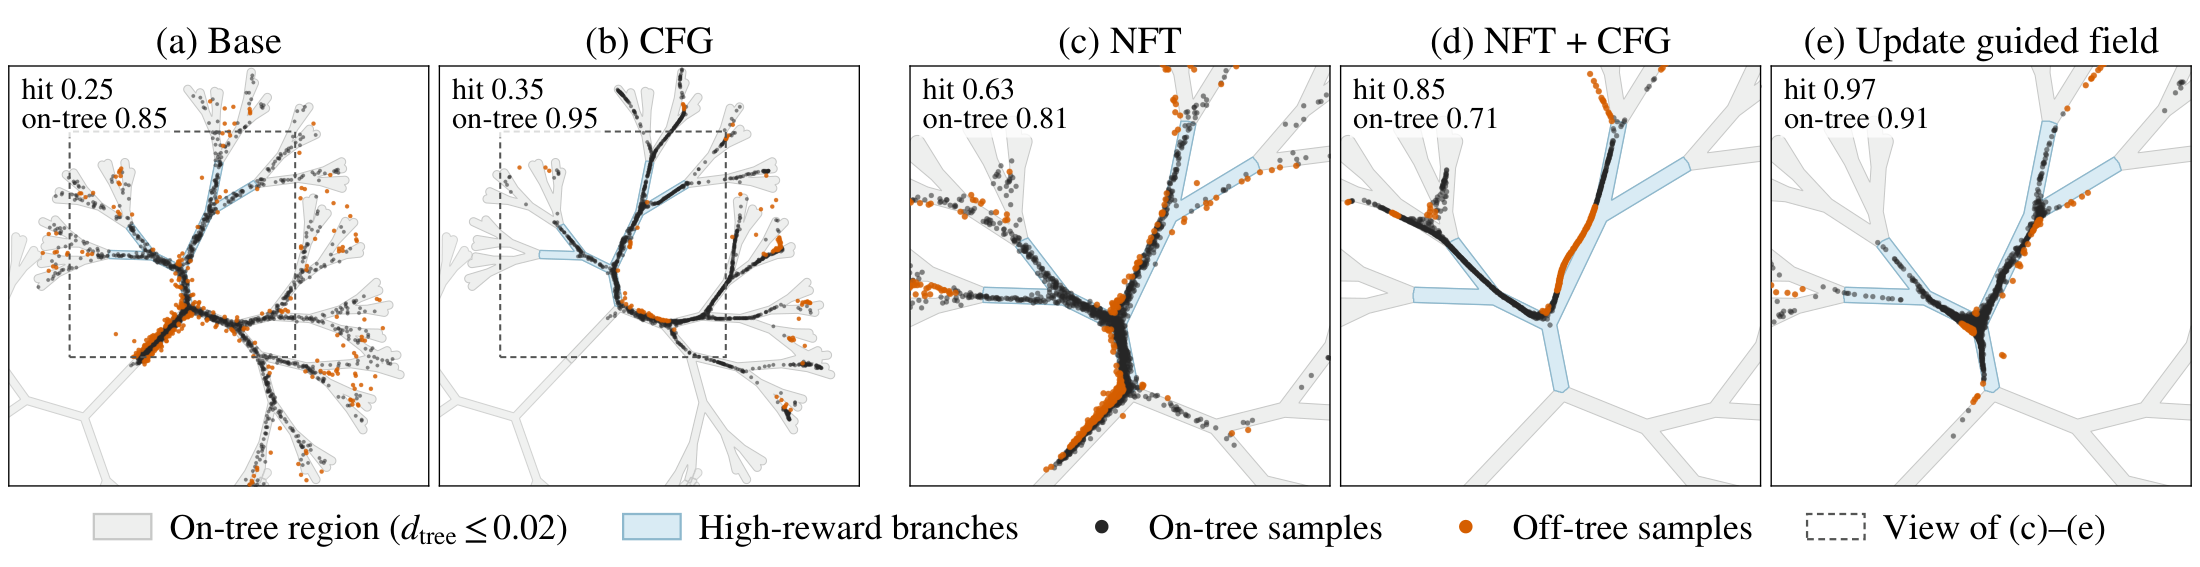
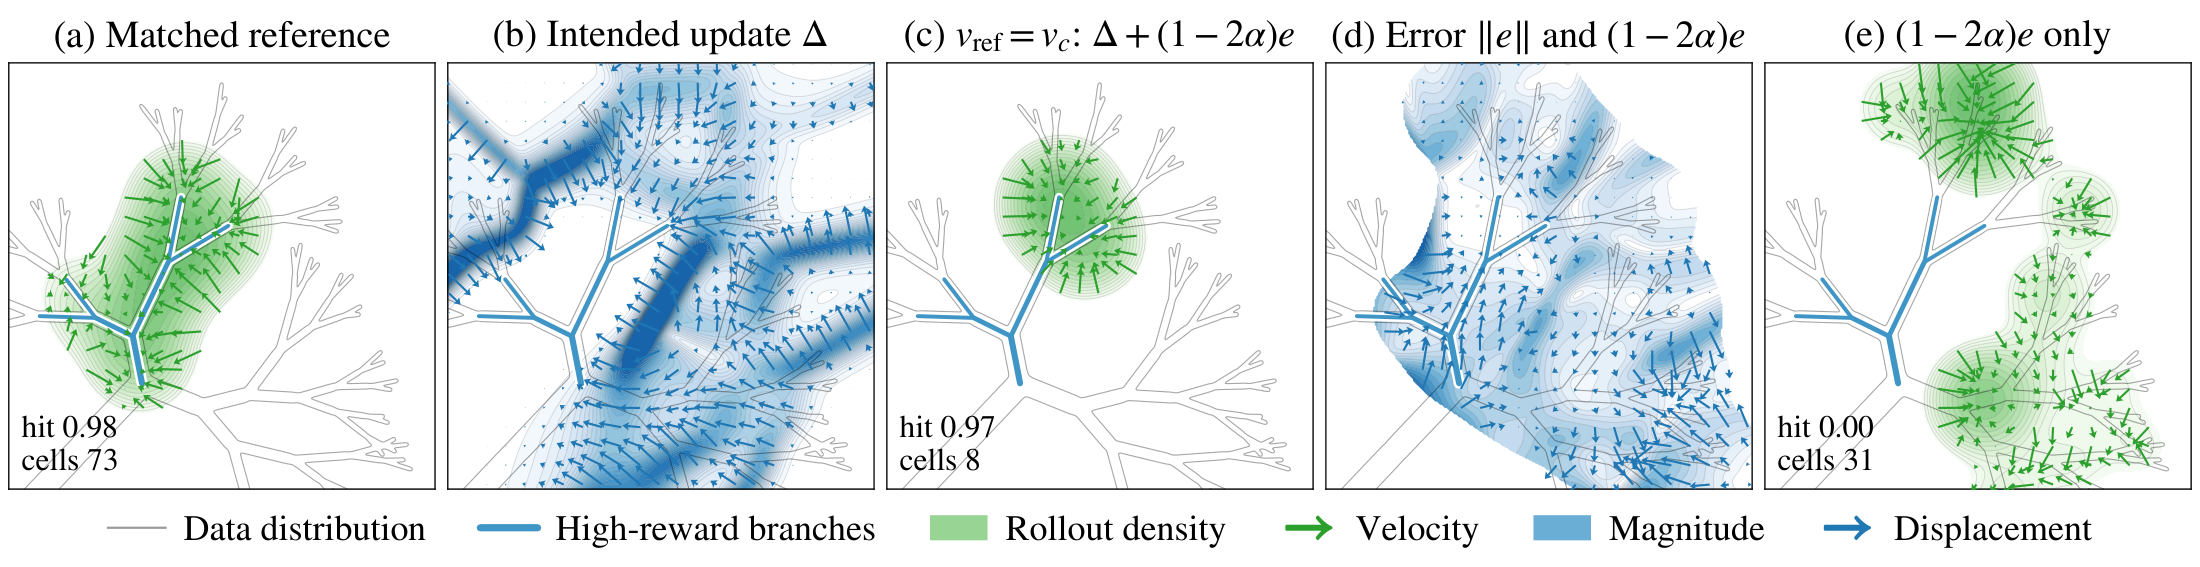
Reward fine-tuning with NFT and classifier-free guidance can undo each other. We trace the
failure to a mismatch in the reference velocity that NFT's two regression terms share, and correct it
with a reference estimated online by flow matching on guided samples. On a toy tree-shaped distribution (above), updating the guided field moves samples
toward the reward target without pushing them off the data (top row), while a mismatched reference
distorts the update and concentrates samples on fewer branches (bottom row).
NeurIPS 2026Princeton University, with Prof. Christine Allen-Blanchette · Jan 2025 – Oct 2025
Structured Phase Space GAN: a conditional generative model that samples an initial state in
a learned latent phase space and evolves it with a port-Hamiltonian network. Cyclic-coordinate regularization
encourages a compact latent representation; analysis of its active directions reveals interpretable
mechanical coordinates from trajectories or video.
Tsinghua IIIS, with Prof. Tao Du · Oct 2025 – Jun 2026
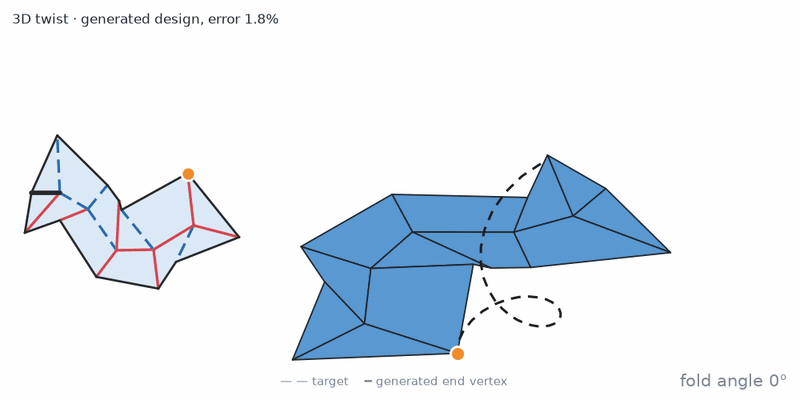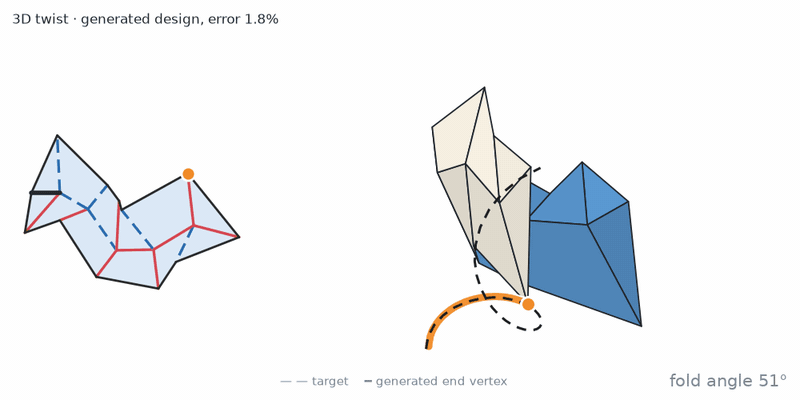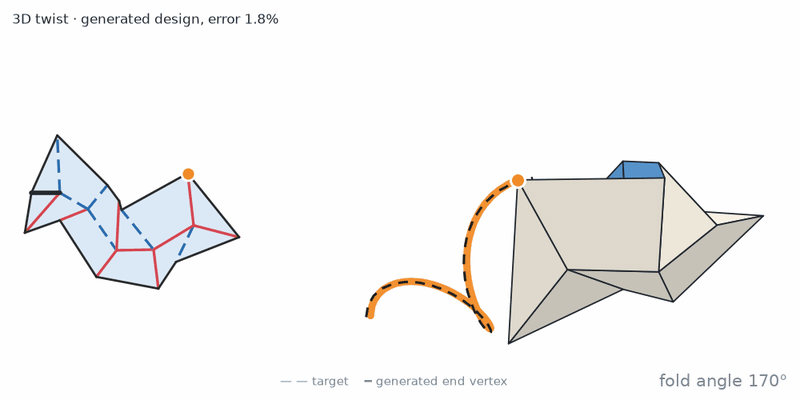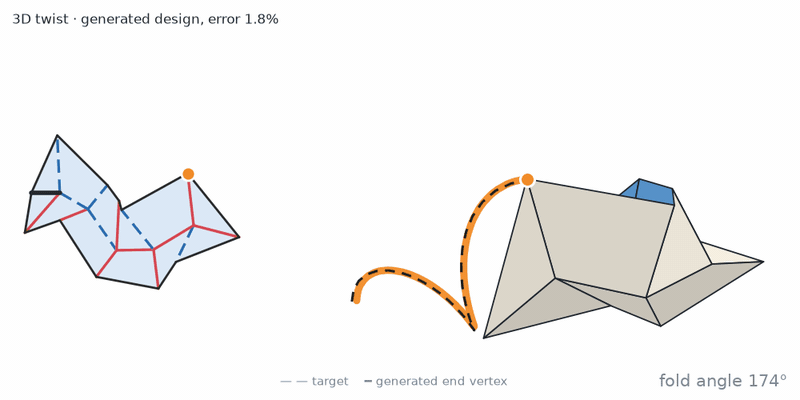
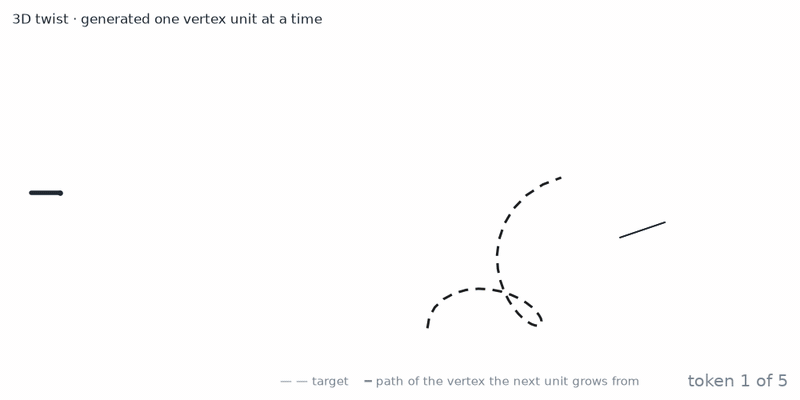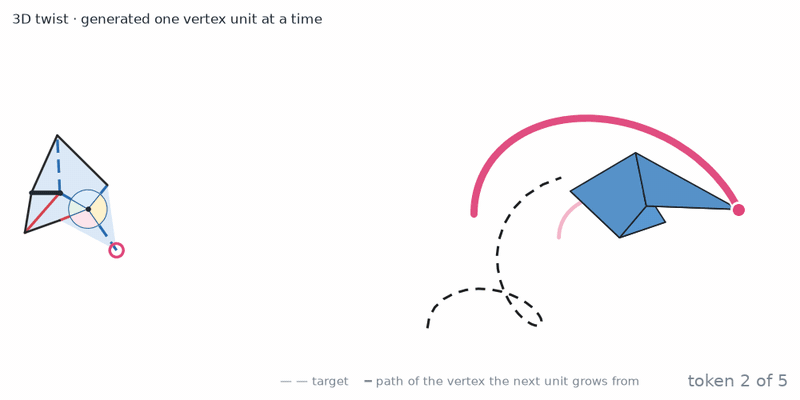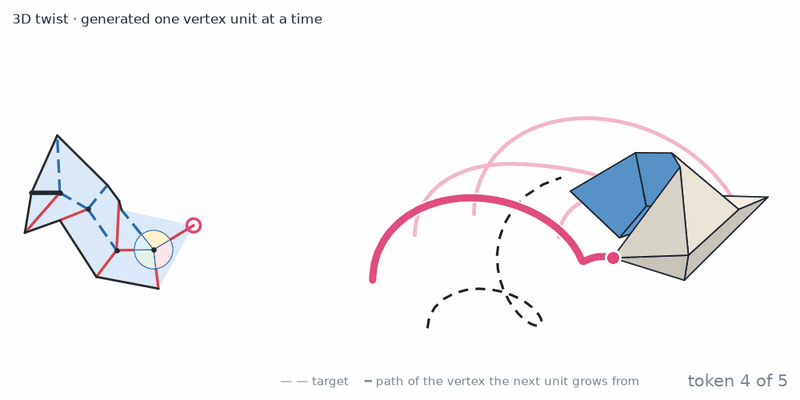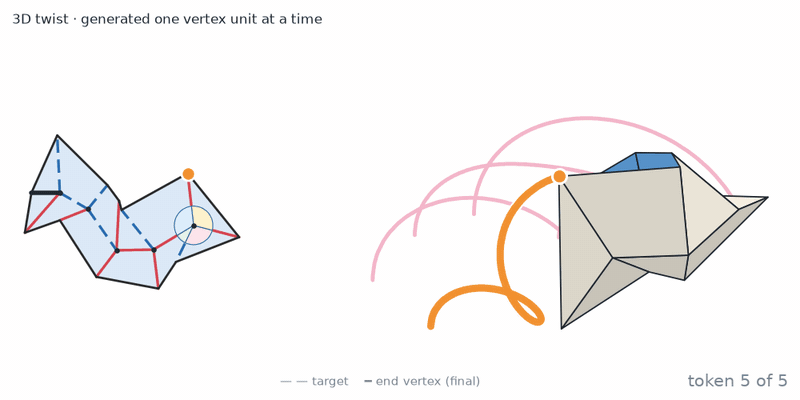
Given a target 3D trajectory, generate a rigid-foldable crease pattern whose folding motion
follows it, with an autoregressive diffusion model that writes the pattern one vertex unit at a time. Above:
the method (top); a generated design folding along a 3D twist, and the same design built unit by unit
(bottom).